06
Autonomous laser-guided drone
I worked on an ESP32 drone prototype with flight-control integration, infrared guidance experiments, and altitude sensing.
- Role
- Embedded systems engineer
- Year
- 2025–2026
- Discipline
- Robotics, controls, sensing
01 Overview
What I built
I explored flight-control integration, guidance, and sensing with an ESP32 drone prototype.
The platform
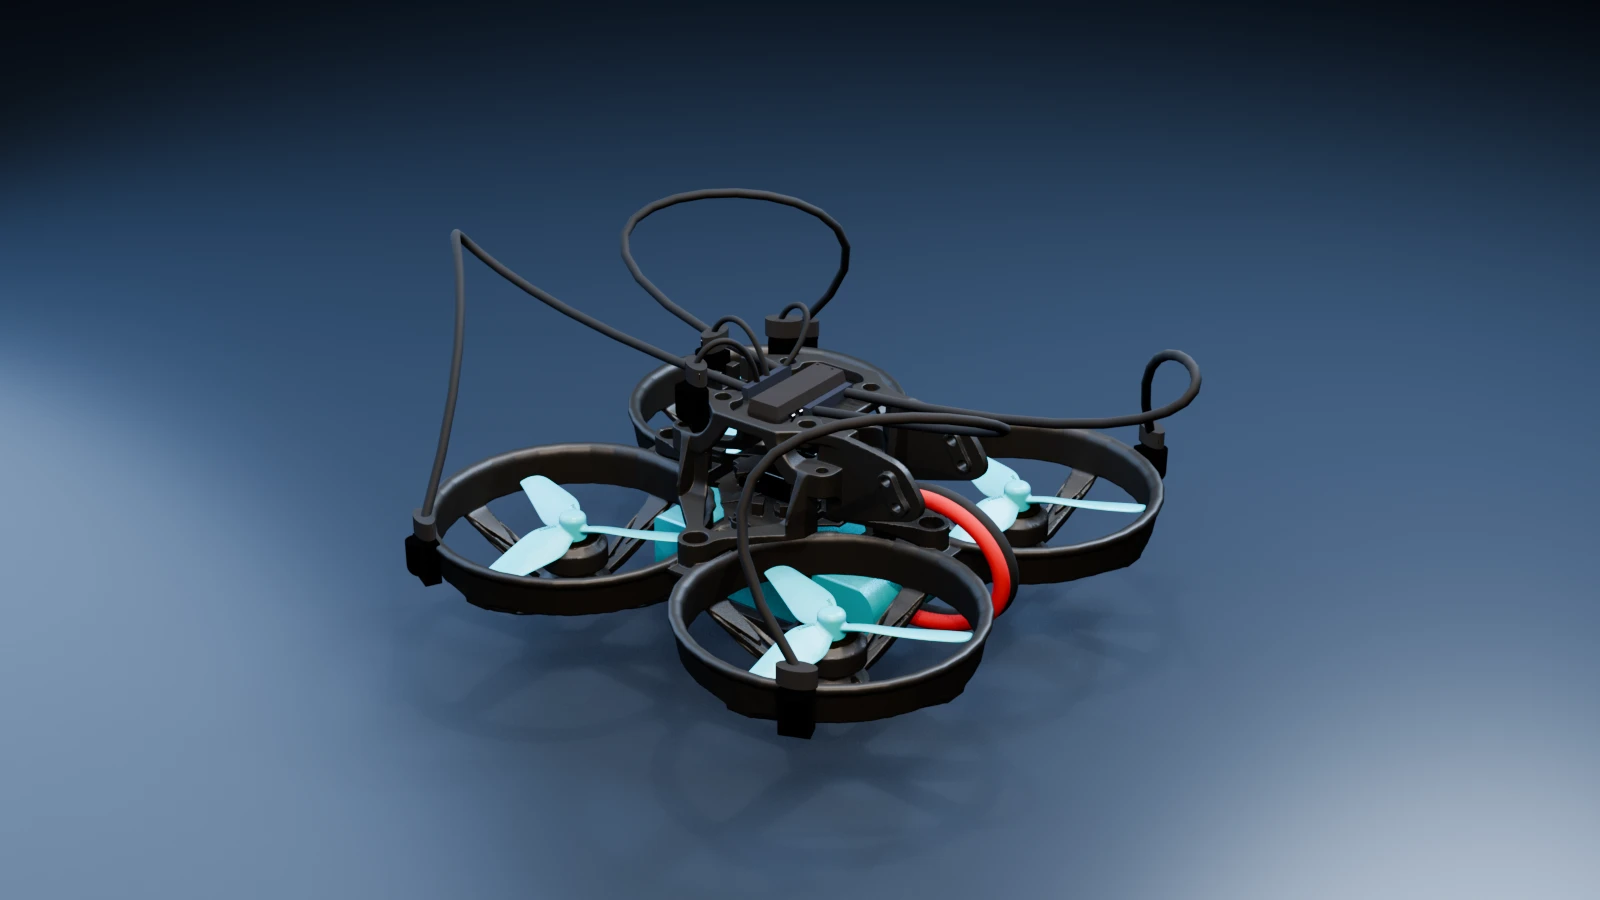
I developed an ESP32 drone prototype with flight-control integration, infrared guidance experiments, and altitude sensing.
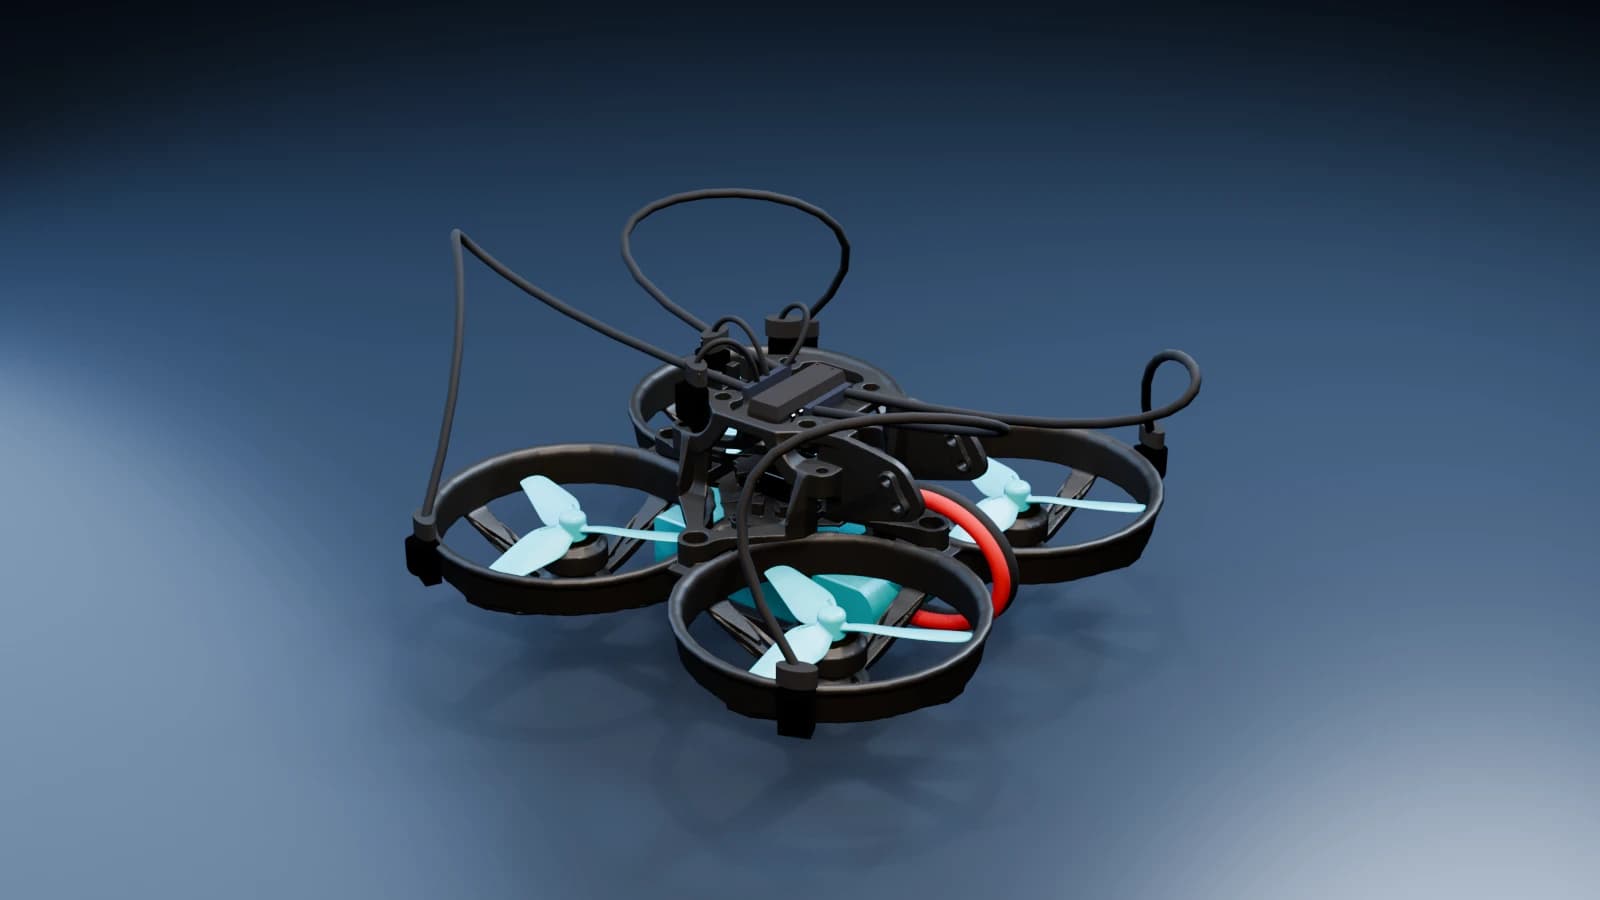
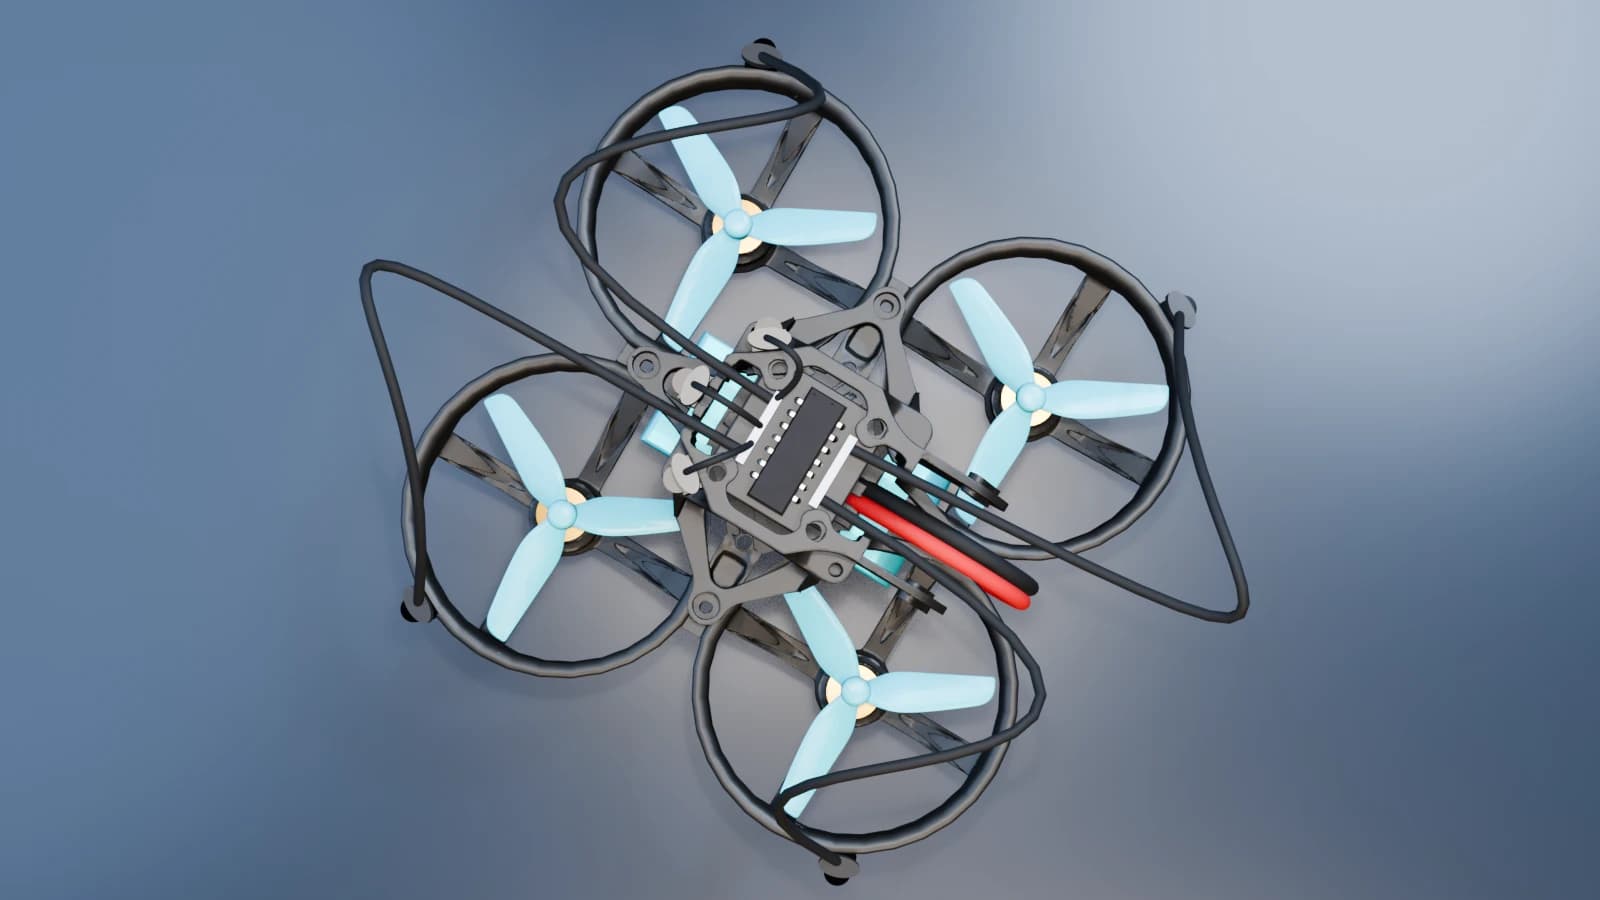
I assembled a compact four-ducted-fan frame to test embedded control and sensor feedback.
02 Challenge
What I tested
I connected a lightweight airframe to stable control, guidance experiments, and altitude feedback.
03 Process
How I integrated it
I focused on integrating the embedded flight loop with a testable physical platform.
The control loop
I combined flight-control integration, motor and frame wiring, infrared guidance experiments, and altitude sensing in the prototype.
I kept each sensing and guidance change within the embedded system boundary so I could evaluate it against the vehicle frame.
04 Outcome
What remains
I documented an embedded flight prototype with room for continued testing.
Where it stands
I built and documented an embedded flight-control and sensing prototype.
I built the hardware setup for guidance and altitude experiments; I have not validated flight yet.
- Status
- Prototype
- Core platform
- ESP32 flight-control integration
- Focus
- Guidance experiments and altitude sensing